QUESTION IMAGE
Question
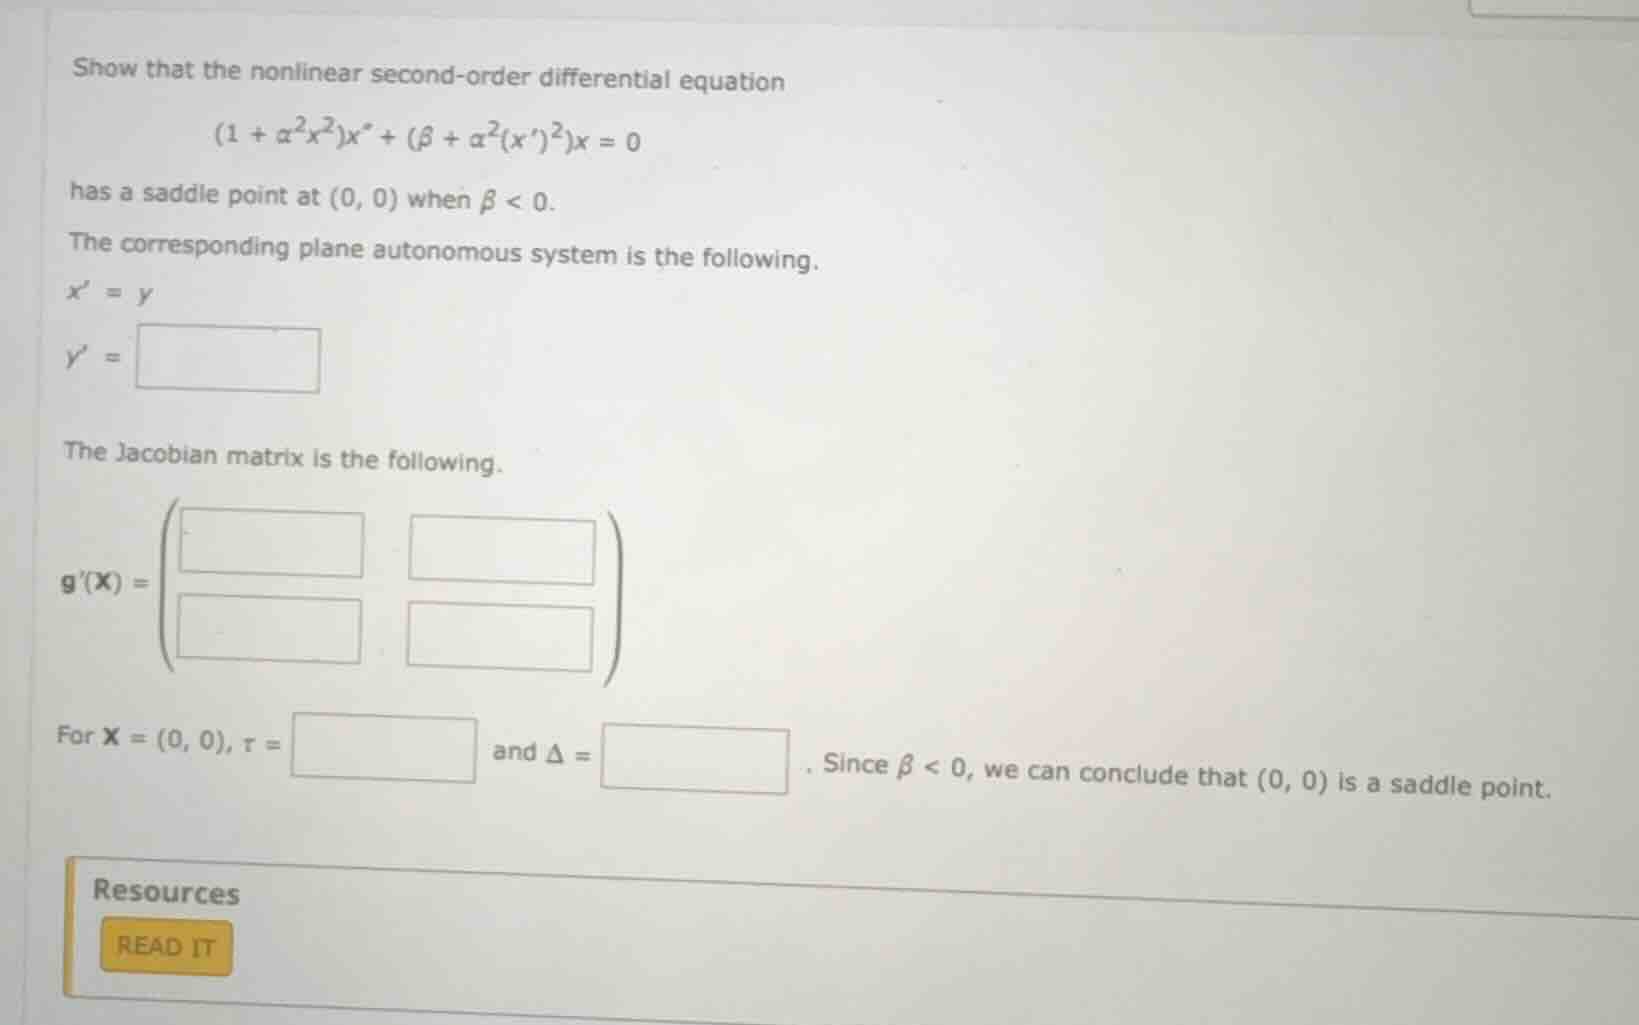
show that the nonlinear second-order differential equation
\\(1 + \alpha^2 x^2)x + (\beta + \alpha^2 (x)^2)x = 0\\
has a saddle point at \\((0, 0)\\) when \\(\beta < 0\\).
the corresponding plane autonomous system is the following.
\\x = y\\
\\y = \\
the jacobian matrix is the following.
\\g(x) = \
\\
for \\(x = (0, 0)\\), \\(\tau = \\) and \\(\delta = \\). since \\(\beta < 0\\), we can conclude that \\((0, 0)\\) is a saddle point.
Convert to a plane autonomous system
Using the Linear Systems of ODEs knowledge point
Compute the partial derivatives for the Jacobian matrix
Using the Linear Systems of ODEs knowledge point
Evaluate the Jacobian matrix at the origin
Using the Phase Portrait Analysis knowledge point
Determine trace and determinant at the origin
Using the Phase Portrait Analysis knowledge point

Snap & solve any problem in the app
Get step-by-step solutions on Sovi AI
Photo-based solutions with guided steps
Explore more problems and detailed explanations
Show that the nonlinear second-order differential equation
has a saddle point at \((0, 0)\) when \(\beta < 0\).
The corresponding plane autonomous system is the following.
\(x' = y\)
\(y' =\) <blank>\(-\frac{(\beta + \alpha^2 y^2)x}{1 + \alpha^2 x^2}\)</blank>
The Jacobian matrix is the following.
For \(\mathbf{X} = (0, 0)\), \(\tau =\) <blank>\(0\)</blank> and \(\Delta =\) <blank>\(\beta\)</blank>. Since \(\beta < 0\), we can conclude that \((0, 0)\) is a saddle point.